Fetching…
Fetching…
Carnegie Mellon University
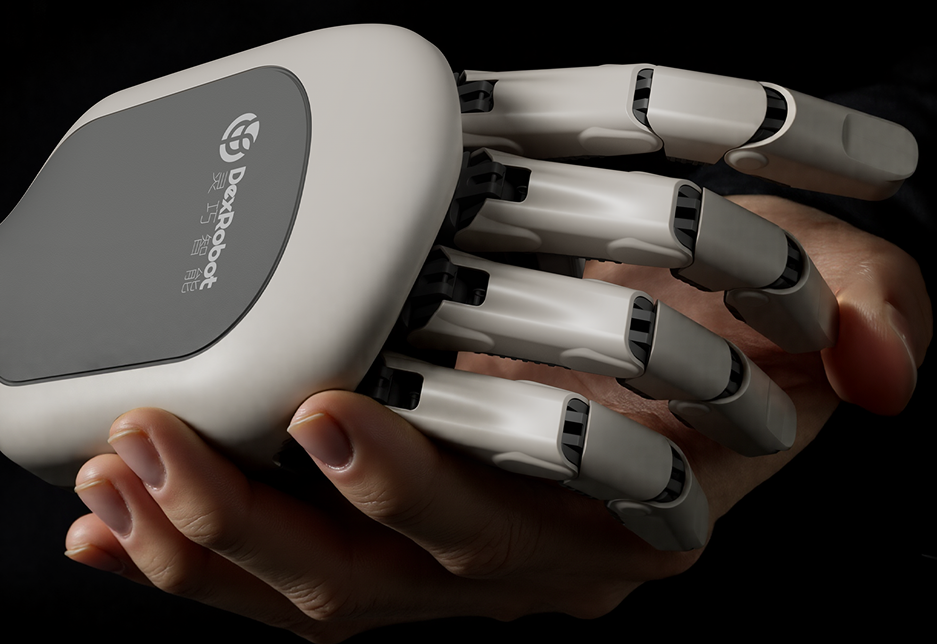
LEAP Hand (Low-Cost End-to-end Affordable Robotic Hand) is an open-source dexterous hand developed at Carnegie Mellon University. With 16 degrees of freedom and a build cost of approximately $2,000, it is designed to democratise dexterous manipulation research. Full CAD files, ROS2 drivers, and simulation assets are freely available. Widely adopted in UK and EU university robotics labs.
| Weight | 0.5 kg |
| Degrees of freedom | 16 |